ENG

PRODUCTS

Software-Defined Motion Control Hardware Solution AMR Solution

WMX (Software-Defined Motion Controller)

WMX is a Software-Defined Motion Controller
developed with Movensys' proprietary SDMC Platform technology.

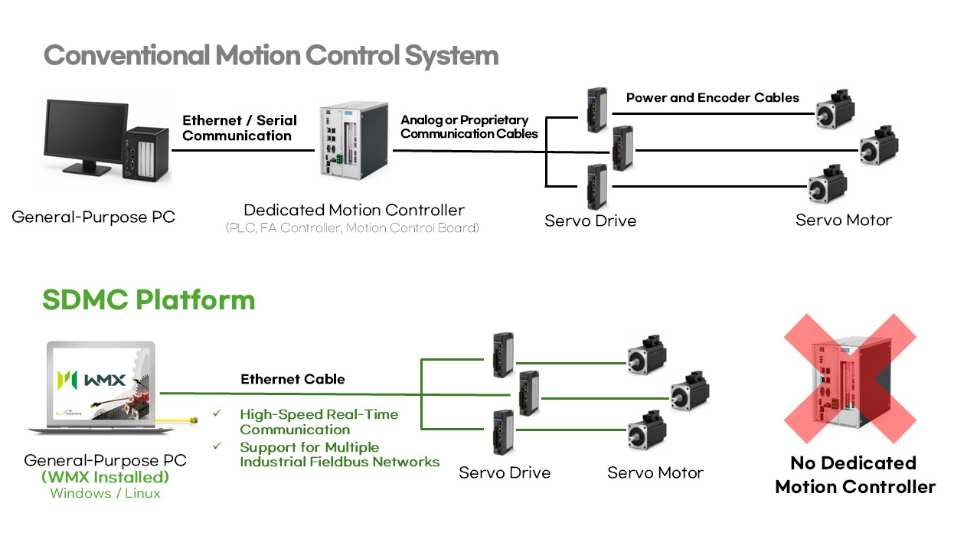
Powered by Movensys’ Software-Defined Motion Control (SDMC) Platform, WMX is a software-only solution that enables machine motion control on a standard Windows PC.
It helps replacing traditional motion controller boards by reducing complex cablings of legacy hardware based systems. Motion control from a single PC simplifies overall system overhead, and customers can customize real-time control threads according to their requirements for high speed and accuracy.​

Features

  • Supports 4- to 128-axis control, including synchronized motion of up to 128 axes, with high-speed communication cycles from 62.5 μs to 8 ms for precise control
  • Obtained the highest level of EtherCAT Master Class, Class A standard Supports EtherCAT, CC-Link IE TSN, and MECHATROLINK-4, with hybrid control across networks
  • Ensures deterministic, real-time control on a real-time OS by dedicating one or more cores of a multi-core CPU
  • Features an open architecture that lets developers build functions beyond the core motion features in C, C++, C#, or Python

WMX R2(One Chip Physical AI)

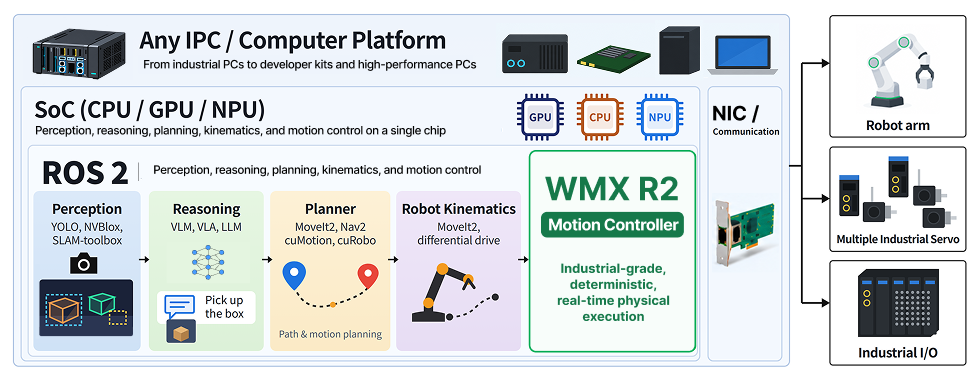
An Industrial-grade Real-time Execution Layer Based on One-Chip for Physical AI

Physical AI를 위한 One Chip 기반 산업용 실시간 실행 계층 이미지
WMX R2 is the real-time execution (Act) layer of Physical AI. Running on the same processor as perception, reasoning, and planning, it receives high-level motion commands and drives devices in real time through servos and industrial networks, minimizing communication latency without a separate motion controller. * ROS 2 is a trademark of Open Source Robotics Foundation.

Core Technology – Industrial Robot Control & Physical AI Integration

  • Integrates the AI decision-making layer and the deterministic real-time control layer on a single chip
  • Expanding from integrated robot control into vibration prediction, model updating, and control policy learning

Key Achievements

  • Poster session presentation at NVIDIA GTC 2026
  • Ongoing development collaboration with Intel on Physical AI control

Key Features

  • Deterministic real-time control powered by the WMX engine, deployed in mass-production industrial equipment since 2014
  • Connects ROS 2 applications to the WMX engine via the shared-memory-based WMX API
  • Controls diverse actuators, including single/multi-axis servos, robot arms, and I/O, through WMX R2 Package modules
  • Integrates with ROS 2 open-source robotics tools such as MoveIt2 and Nav2
  • Runs as a single software stack across platforms including Intel®-based industrial PCs and NVIDIA Jetson
  • Available to developers through APIs, SDKs, and GitHub

Applications

Semiconductor

Front/Back-end Process (Photo, Etching, Wet/Dry Cleaner, Inspection)

Wafer Transfer Robot

Stocker/OHT/AMR

01

Display

Front/Back-end Process (Cleaner, Exposure, Coater, Etcher, Inspection)

Glass Transfer Robot

Stocker/OHS/AMR

02

Smart Device

Camera Inspection

Flex Bending/Dispenser/Assembly

SCARA Robot

03

Secondary Cell (EV Battery)

Stacking/Packaging/Welding

Activation Process

OHT/AMR

04

  • 01

    Semiconductor

  • 02

    Display

  • 03

    Smart Device

  • 04

    Secondary Cell (EV Battery)

Core Technology – SDMC Platform

Movensys’ SDMC Platform is composed of a communication-optimized Soft Master, real-time modular synchronization, and dynamic channel management technologies. Through a highly optimized modular and open architecture (patented by Movensys), SDMC Platform offers broad compatibility with various software platforms and networks.
모벤텍쳐 설계도 이미지
  • ▧ Hard Real-Time Control on General-Purpose OS
    • Stores control commands from a general-purpose OS (Windows/Linux) in memory channels and buffers, delivering them on cycle to maintain strict periodicity
    • Stable control through automatic updates at precise intervals on a real-time OS
    • Flexible sequence configuration with freely adjustable control cycles
  • ▧ Large-Scale Multi-Axis Synchronized Motion Control
    • Synchronizes multiple axes to a defined time base
    • Processes position, velocity, trajectory, and interpolation commands in real time
    • Fast, accurate computation through a unified command set independent of network type
  • ▧ Multi-Protocol Soft Master
    • Implements master functions for industrial networks such as EtherCAT, CC-Link IE TSN, and MECHATROLINK-4 in software, without dedicated hardware
    • Supports various networks by simply switching interfaces, thanks to separated control and communication modules
    • Runs heterogeneous communication protocols simultaneously to connect different devices and maximize hardware scalability
    • Broad compatibility with slave hardware based on standard industrial communication protocols
  • ▧ Open Control Platform
    • Layered architecture of real-time engine, communication, motion, and application software, scaling functions to match equipment configuration
    • Public API library for custom sequence development and customization
    • Seamless integration with third-party programs beyond motion control
    • Automatically generated status monitoring for optimal system resource management

Upcoming Product

WMX Ultra

(WMX High-end Solution)

High-performance, high-precision motion control - the high-end solution for WMX